Avoidance scenario#
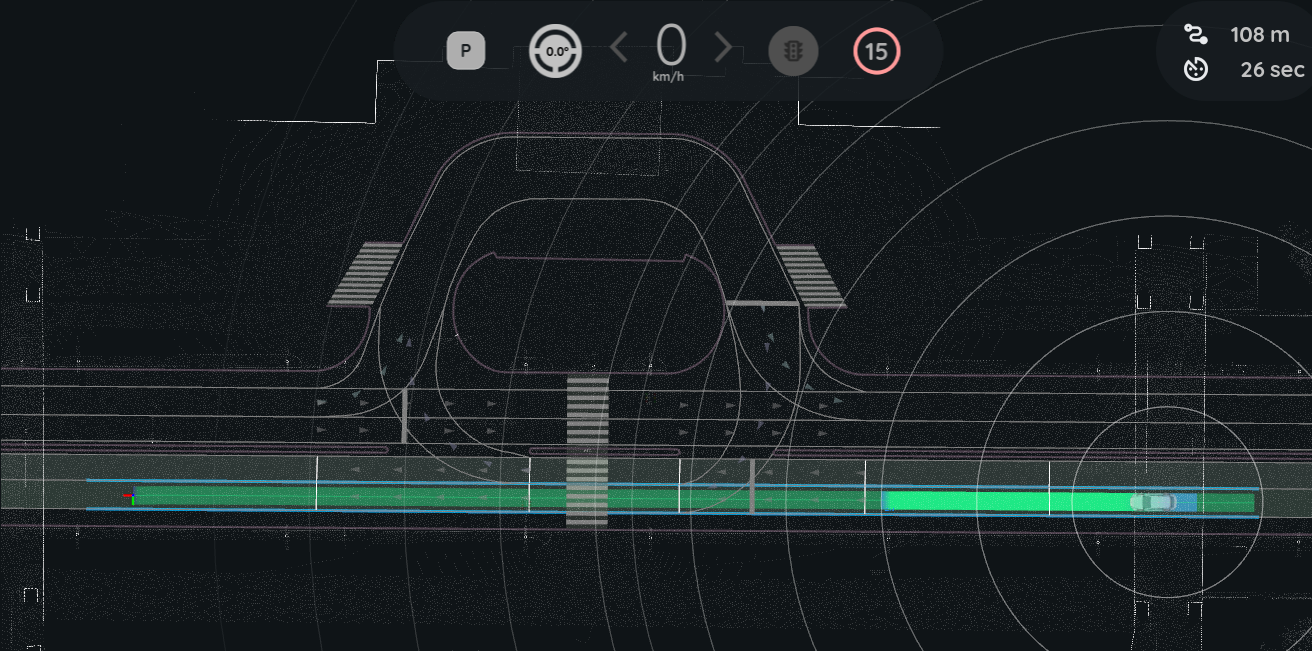
Set an initial pose and a goal pose in the same lane. A path will be planned.
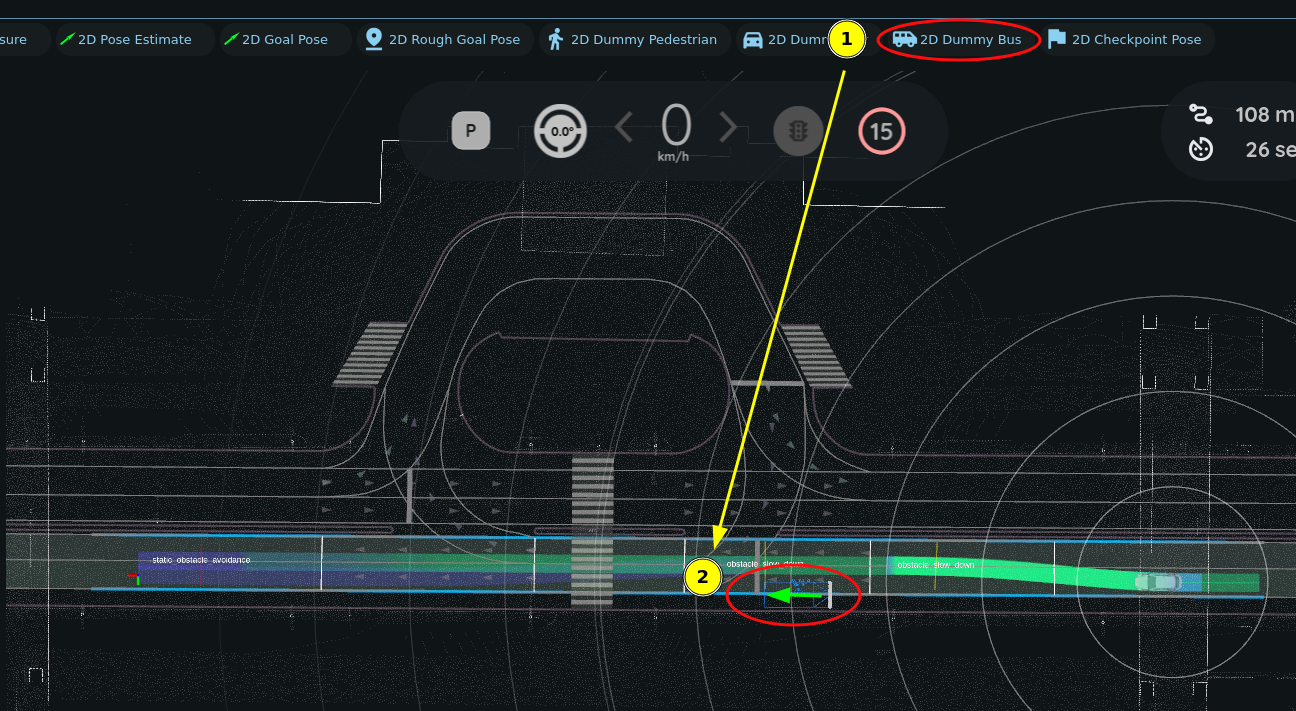
Set a "2D Dummy Bus" on the roadside. A new path will be planned.
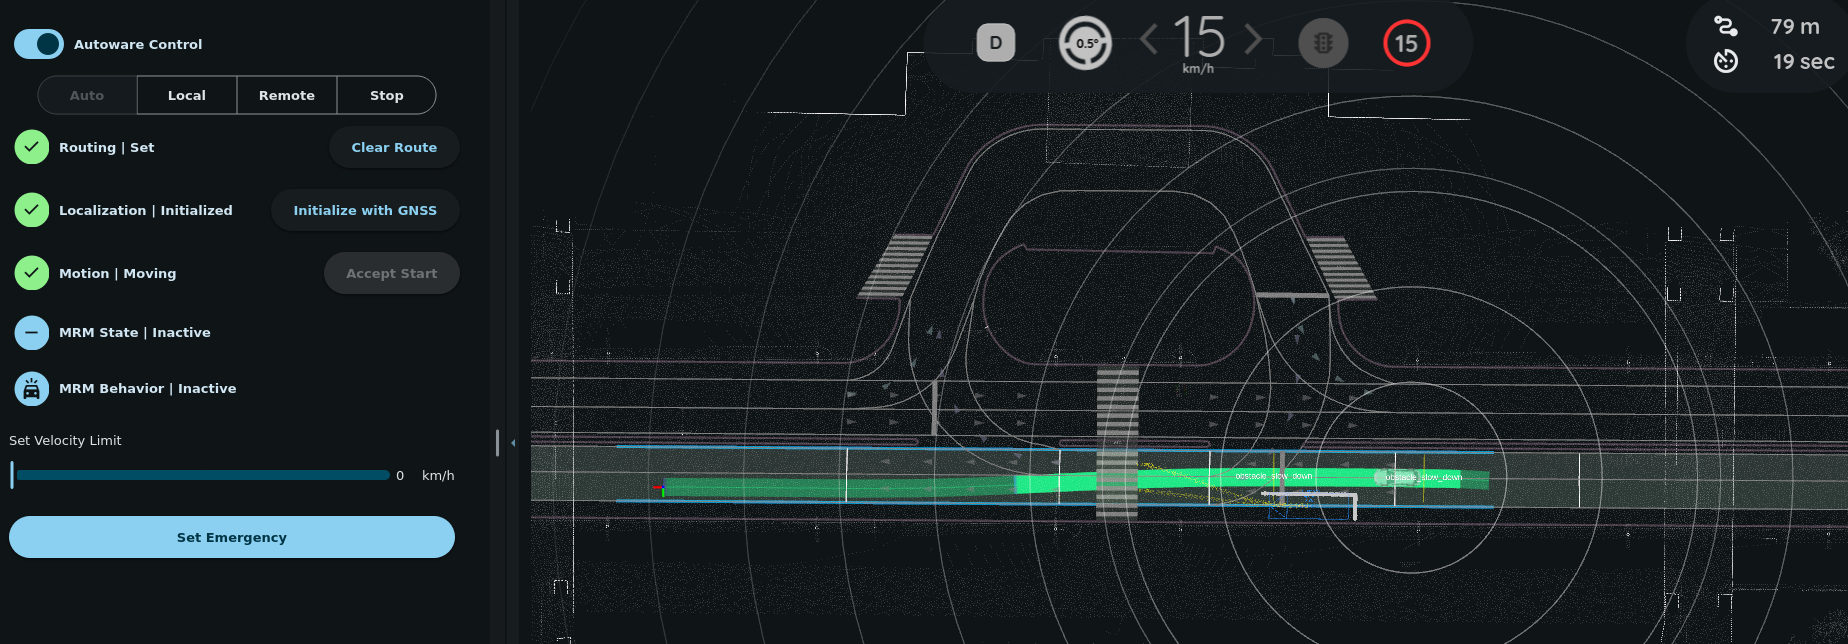
Engage the ego vehicle. It will avoid the obstacle along the newly planned path.
Set an initial pose and a goal pose in the same lane. A path will be planned.
Set a "2D Dummy Bus" on the roadside. A new path will be planned.
Engage the ego vehicle. It will avoid the obstacle along the newly planned path.