Crosswalk attribute#
Behavior velocity planner's crosswalk module plans velocity to stop or decelerate for pedestrians approaching or walking on a crosswalk. In order to operate that, we will add crosswalk attribute to our lanelet2 map.
Creating a crosswalk attribute#
In order to create a crosswalk on your map, please follow these steps:
- Click
Abstractionbutton on top panel. - Select
Crosswalkfrom the panel. - Click and draw crosswalk on your pointcloud map.
You can see these steps in the crosswalk creating demonstration video:
Testing created crosswalk with planning simulator#
After the completing of creating the map, we need to save it. To that please click File --> Export Lanelet2Maps then download.
After the download is finished, we need to put lanelet2 map and pointcloud map on the same location. The directory structure should be like this:
<YOUR-MAP-DIRECTORY>/
 ├─ pointcloud_map.pcd
 ├─ lanelet2_map.osm
 └─ map_projector_info.yaml
The map_projector_info.yaml file tells Autoware the projection of the map. Write the MGRS grid that you entered when you created the Lanelet2 map in Vector Map Builder:
projector_type: MGRS
vertical_datum: WGS84
mgrs_grid: <YOUR-MGRS-GRID> # for example, 35TPF
Use the vertical datum of your point cloud map. For a point cloud map from the UTM to MGRS converter, use EGM2008. If the file does not exist, Autoware reads the MGRS grid from the Lanelet2 map. This fallback is deprecated.
If your .osm or .pcd map file's name is different from these names, add the lanelet2_map_file and pointcloud_map_file arguments to the launch command:
ros2 launch autoware_launch planning_simulator.launch.xml map_path:=<YOUR-MAP-FOLDER-DIR> vehicle_model:=<YOUR-VEHICLE-MODEL> sensor_model:=<YOUR-SENSOR-KIT> lanelet2_map_file:=<YOUR-LANELET-MAP-NAME>.osm pointcloud_map_file:=<YOUR-POINTCLOUD-MAP-NAME>.pcd
Now we are ready to launch the planning simulator:
ros2 launch autoware_launch planning_simulator.launch.xml map_path:=<YOUR-MAP-FOLDER-DIR> vehicle_model:=<YOUR-VEHICLE-MODEL> sensor_model:=<YOUR-SENSOR-KIT>
Example for tutorial_vehicle:
ros2 launch autoware_launch planning_simulator.launch.xml map_path:=$HOME/autoware_data/maps/tutorial_map/ vehicle_model:=tutorial_vehicle sensor_model:=tutorial_vehicle_sensor_kit vehicle_id:=tutorial_vehicle
- Click
2D Pose Estimatebutton on rviz or pressPand give a pose for initialization. - Click
2D Goal Posebutton on rviz or pressGand give a pose for goal point. - We need to add pedestrians to crosswalk, so activate interactive pedestrians from
Tool Propertiespanel on rviz. - After that, please press
Shift, then click right click button for inserting pedestrians. - You can control inserted pedestrian via dragging right click.
For more information about interactive dummy objects, see placing interactive dummy objects.
Crosswalk markers on rviz:
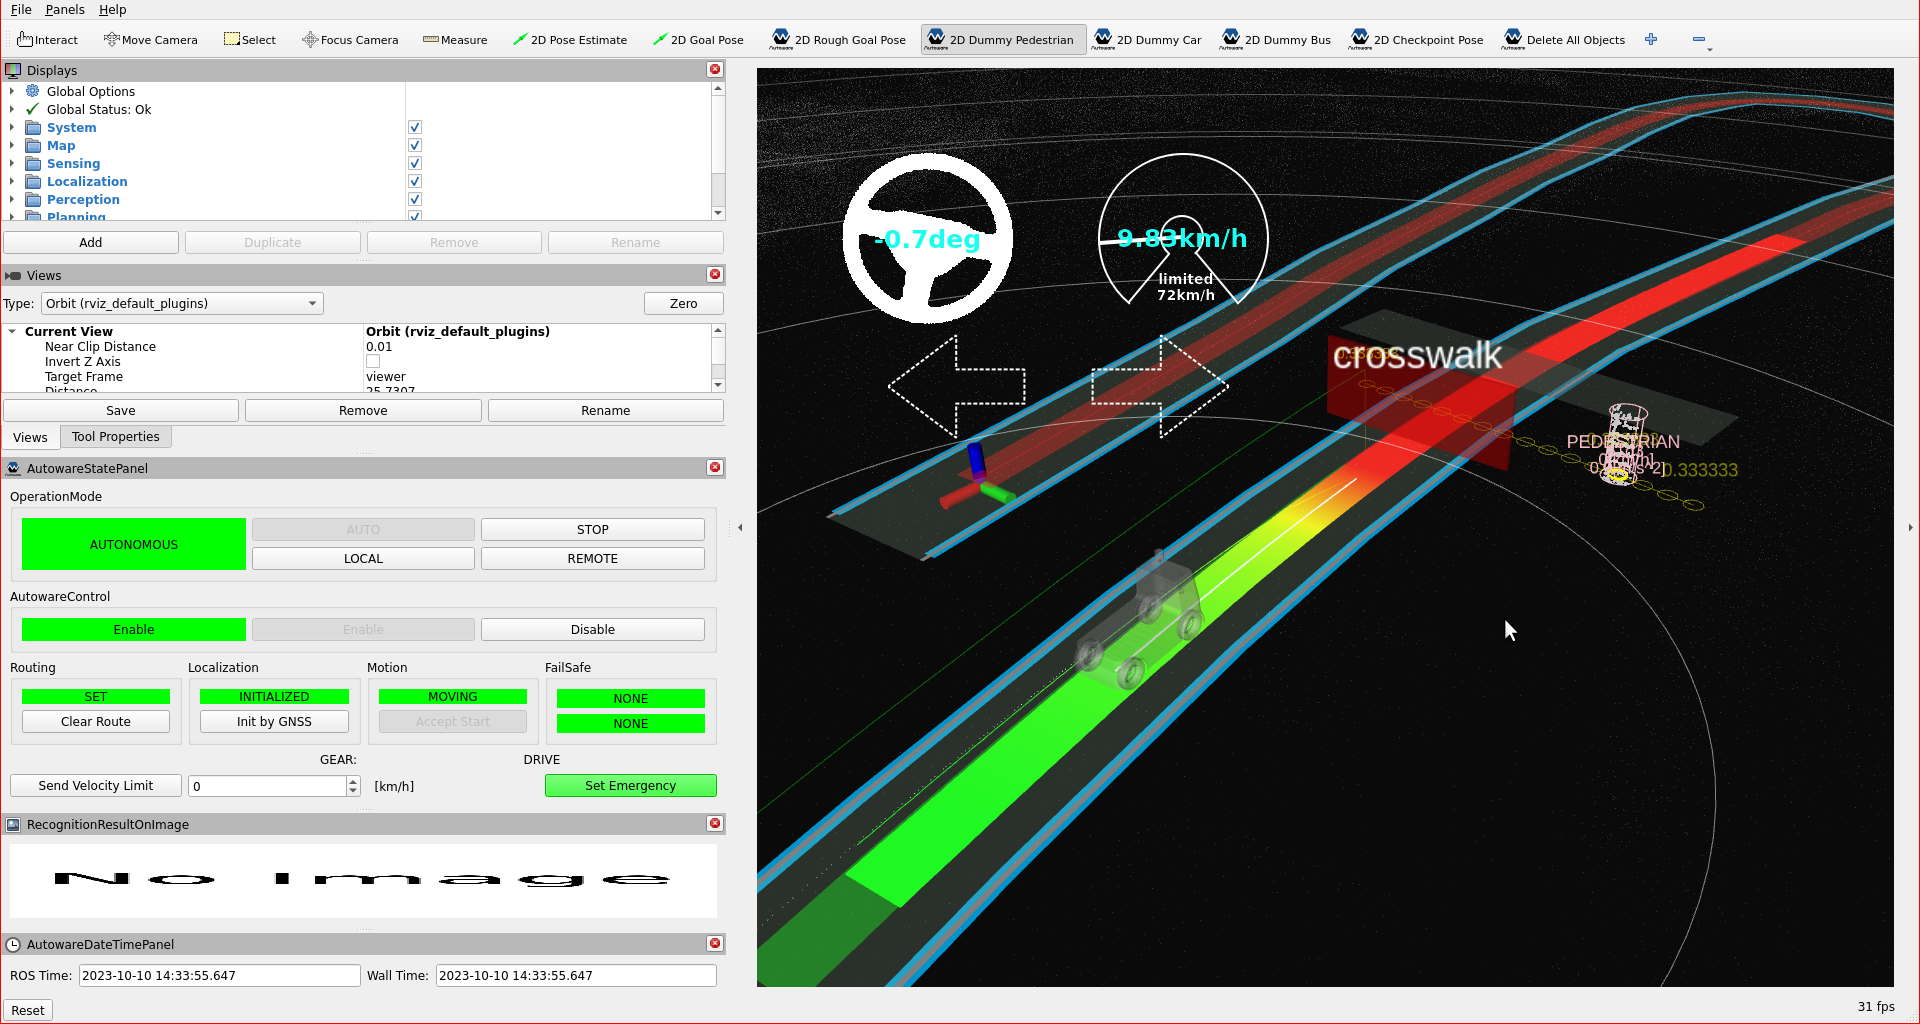
You can check your crosswalk elements in the planning simulator as this demonstration video: