Speed bump#
Behavior velocity planner's speed bump module plans velocity to slow down before speed bump for comfortable and safety driving. In order to operate that, we will add speed bumps to our lanelet2 map.
Creating a speed bump element#
In order to create a speed bump on your pointcloud map, please follow these steps:
- Select
Linestringfrom Lanelet2Maps section. - Click and draw polygon for speed bump.
- Then please disable
Linestringfrom Lanelet2Maps section. - CLick
Change to Polygonfrom theActionpanel. - Please select this Polygon and enter
speed_bumpas the type. - Then, please click lanelet which speed bump to be added.
- Select
Create General Regulatory ELement. - Go to this element, and please enter
speed_bumpas subtype. - Click
Add refersand type your created speed bump polygon ID.
You can see these steps in the speed bump creating demonstration video:
Testing created the speed bump element with planning simulator#
After the completing of creating the map, we need to save it. To that please click File --> Export Lanelet2Maps then download.
After the download is finished, we need to put lanelet2 map and pointcloud map on the same location. The directory structure should be like this:
<YOUR-MAP-DIRECTORY>/
 ├─ pointcloud_map.pcd
 ├─ lanelet2_map.osm
 └─ map_projector_info.yaml
The map_projector_info.yaml file tells Autoware the projection of the map. Write the MGRS grid that you entered when you created the Lanelet2 map in Vector Map Builder:
projector_type: MGRS
vertical_datum: WGS84
mgrs_grid: <YOUR-MGRS-GRID> # for example, 35TPF
Use the vertical datum of your point cloud map. For a point cloud map from the UTM to MGRS converter, use EGM2008. If the file does not exist, Autoware reads the MGRS grid from the Lanelet2 map. This fallback is deprecated.
If your .osm or .pcd map file's name is different from these names, add the lanelet2_map_file and pointcloud_map_file arguments to the launch command:
ros2 launch autoware_launch planning_simulator.launch.xml map_path:=<YOUR-MAP-FOLDER-DIR> vehicle_model:=<YOUR-VEHICLE-MODEL> sensor_model:=<YOUR-SENSOR-KIT> lanelet2_map_file:=<YOUR-LANELET-MAP-NAME>.osm pointcloud_map_file:=<YOUR-POINTCLOUD-MAP-NAME>.pcd
Note
The speed bump module is not enabled by default. To enable it, set the default value of launch_speed_bump_module to "true" in default_preset.yaml. If you did not build Autoware with --symlink-install, build the autoware_planning_config package again. The module parameters are in speed_bump.param.yaml.
Now we are ready to launch the planning simulator:
ros2 launch autoware_launch planning_simulator.launch.xml map_path:=<YOUR-MAP-FOLDER-DIR> vehicle_model:=<YOUR-VEHICLE-MODEL> sensor_model:=<YOUR-SENSOR-KIT>
Example for tutorial_vehicle:
ros2 launch autoware_launch planning_simulator.launch.xml map_path:=$HOME/autoware_data/maps/tutorial_map/ vehicle_model:=tutorial_vehicle sensor_model:=tutorial_vehicle_sensor_kit vehicle_id:=tutorial_vehicle
- Click
2D Pose Estimatebutton on rviz or pressPand give a pose for initialization. - Click
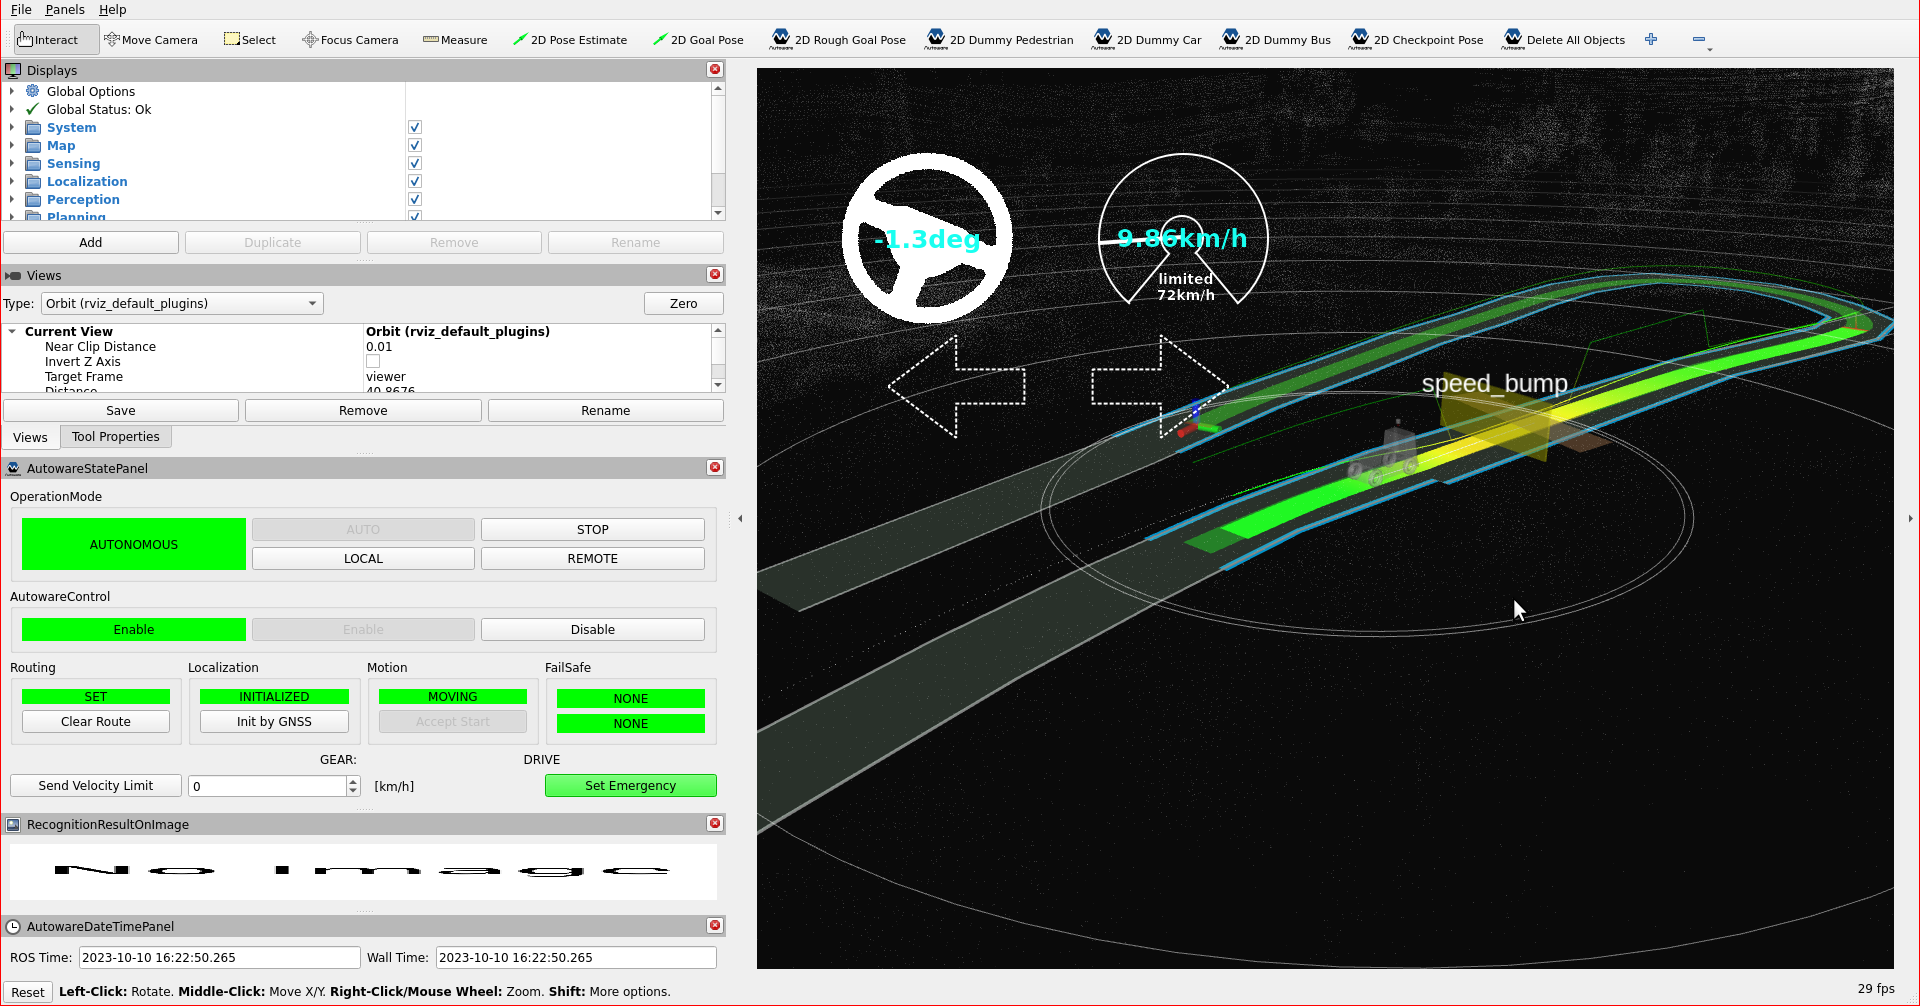
2D Goal Posebutton on rviz or pressGand give a pose for goal point. - You can see the speed bump marker on the rviz screen.
Speed bump markers on rviz:
You can check your speed bump elements in the planning simulator as this demonstration video: